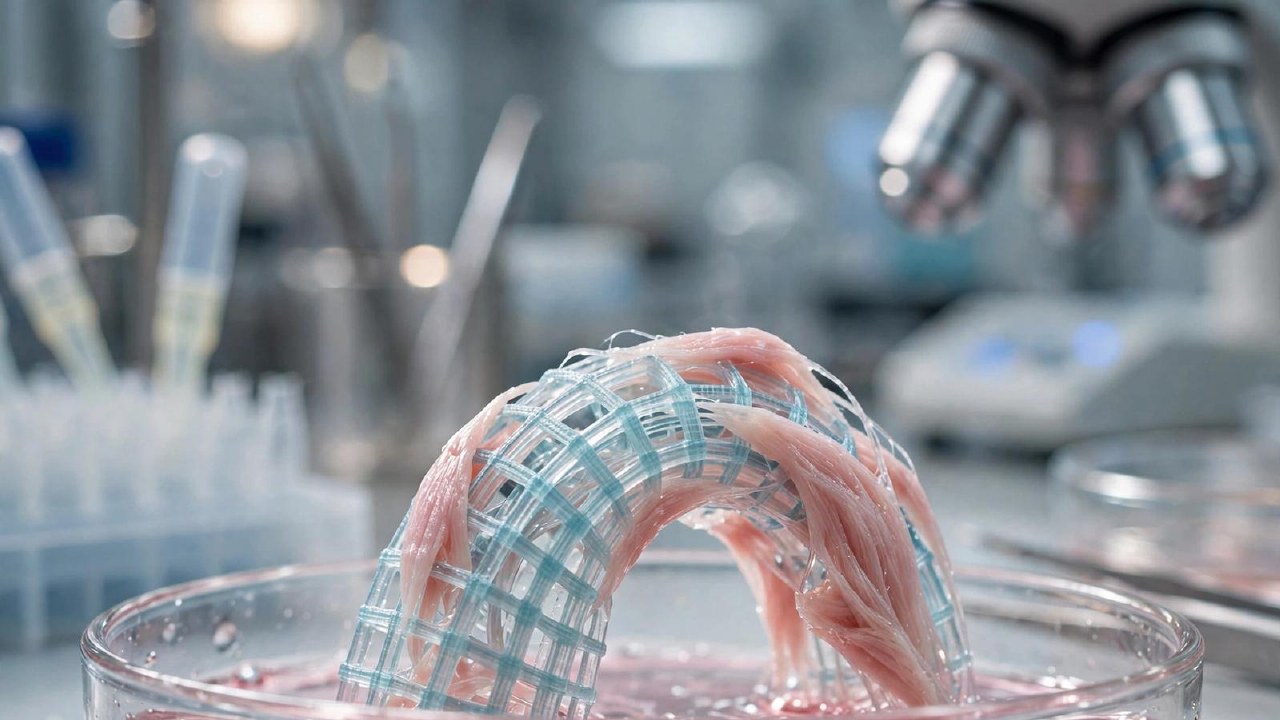
Researchers at ETH Zurich have developed bio-actuators powered by living muscle tissue that can jump, swim, and grasp objects. These new systems demonstrate a performance range eleven times greater than previous designs with similar amounts of muscle tissue.
Led by Professor Robert Katzmann, the team utilized a new design approach where the geometry of the muscle and the soft hydrogel frame are calculated simultaneously via computer algorithms. This method maximizes the deformation of the structure during muscle contraction.
The actuators, measuring approximately 1.5 centimeters in length, can jump 5 millimeters high. A walking version achieved a speed of 6.2 mm/s, which is a record for bio-hybrid robots. The design uses small grooves on a 3D-printed frame to anchor muscle fibers and ensure efficient force transmission.
Despite these advancements, the robots currently require a nutrient solution to function. The researchers identify the development of an artificial vascular system for oxygen and nutrient delivery as the primary challenge for scaling the technology beyond laboratory conditions.