

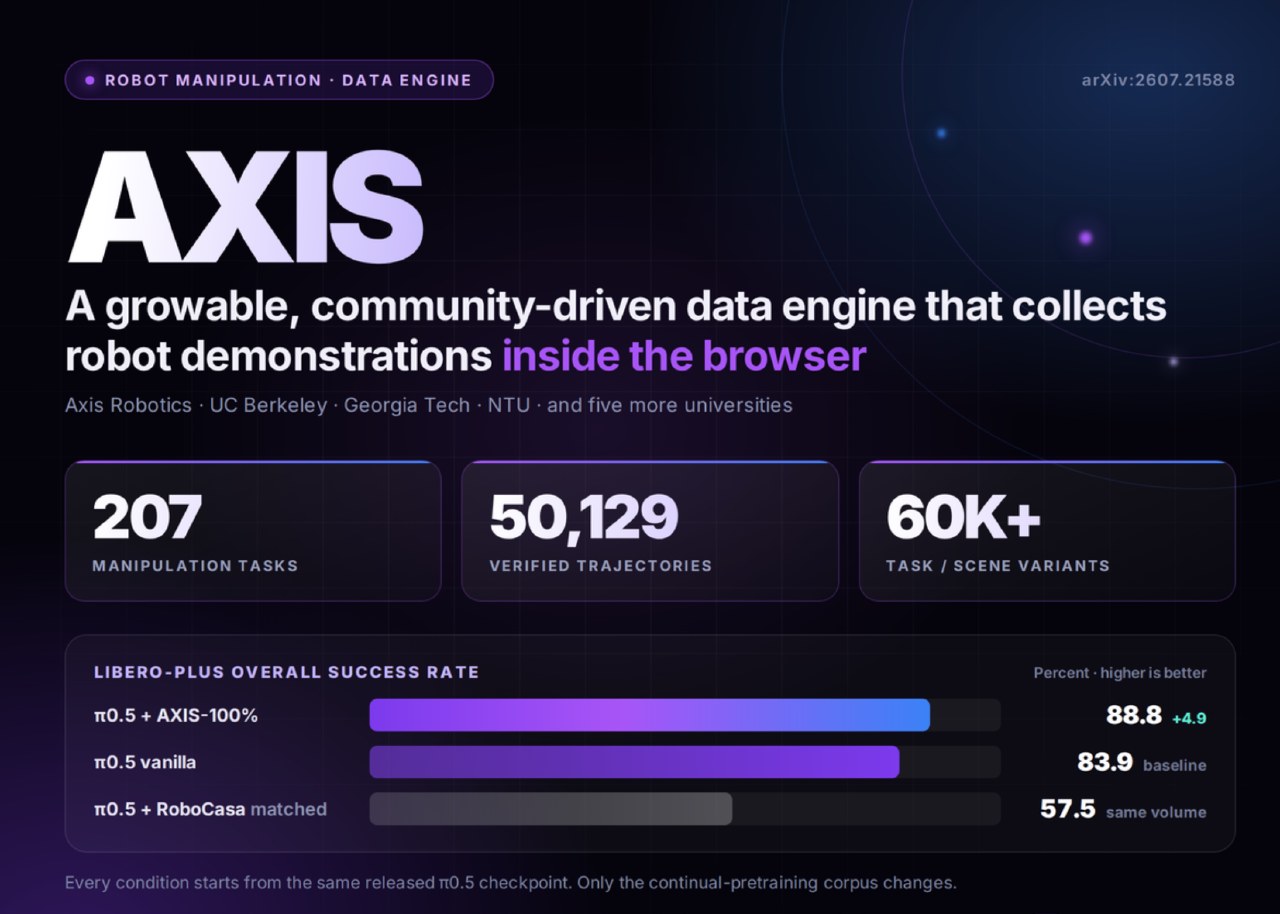
Axis Robotics has launched AXIS, a browser-based data engine for robot manipulation. The platform features 207 tasks and 50,129 episodes, with over 60,000 task or scene variants across seven categories. The dataset is hosted on Hugging Face, spans 2.36 TB, and is restricted to non-commercial academic use.
The system utilizes a TaskGen pipeline to generate tasks by decomposing language instructions into scene and object configurations. A layout supervisor validates the scenes, while a backend success checker verifies task completion. The project credits more than 70,000 community members for their contributions to the data collection.
Data processing involves filtering static samples and smoothing motion using a Savitzky-Golay filter. Trajectories are resampled from 6–8 Hz to 20 Hz. Cleaned episodes are replayed in IsaacSim with randomized lighting and camera settings to produce ray-traced RGB observations.
The training pipeline uses a PaliGemma Gemma-2B backbone with a Gemma-300M action expert. The model undergoes 100,000 steps of pretraining followed by 30,000 steps of fine-tuning on LIBERO. The AXIS-100% model achieves an 88.8 score on LIBERO-Plus, compared to 83.9 for the baseline.



