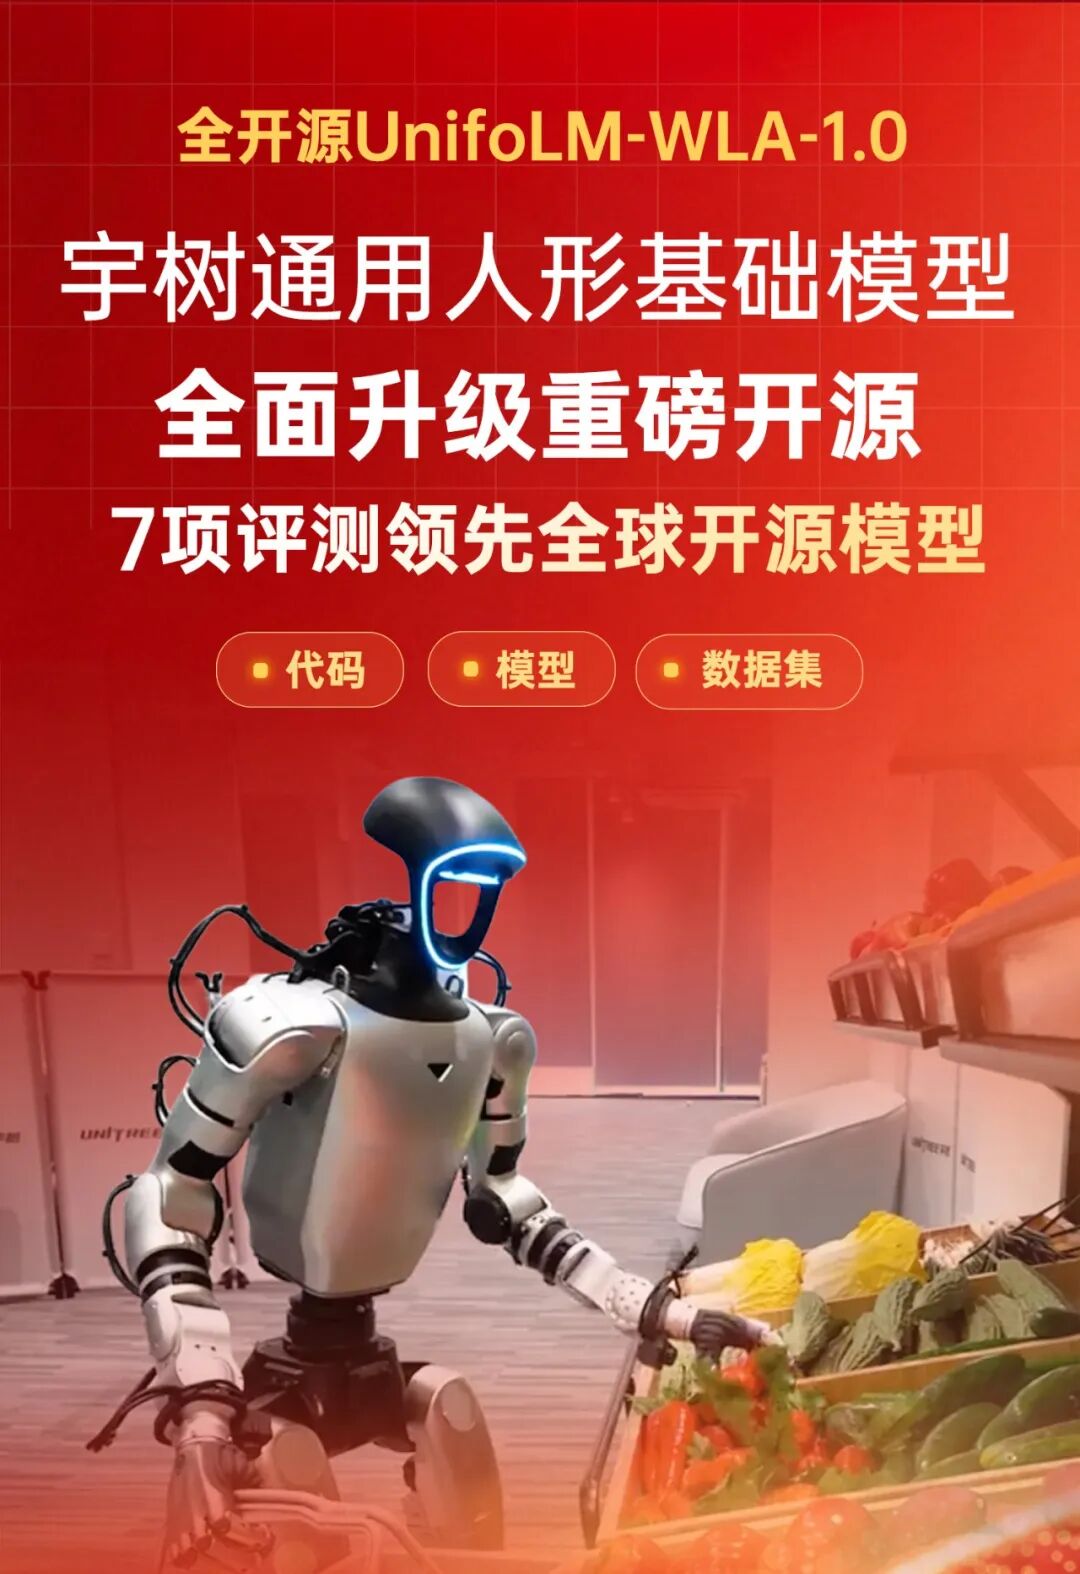
Unitree Robotics has officially released its new UnifoLM-WLA-1.0 embodied foundation model as an open-source project. The company claims the model has achieved state-of-the-art results across several global open-source benchmarks, matching the performance of leading closed-source alternatives.
The model utilizes large-scale multimodal perception and interaction-centric world modeling to improve spatial understanding. It is designed to handle both desktop-based tasks and full-body mobile operations within a single architecture, allowing for generalization across various tasks and end-effectors.
During real-world testing, the UnifoLM-WLA-1.0 model successfully managed 64 distinct tasks. The system demonstrates capabilities in cross-task execution and adaptability to different hardware configurations, marking a significant step in the development of general-purpose humanoid robot control.