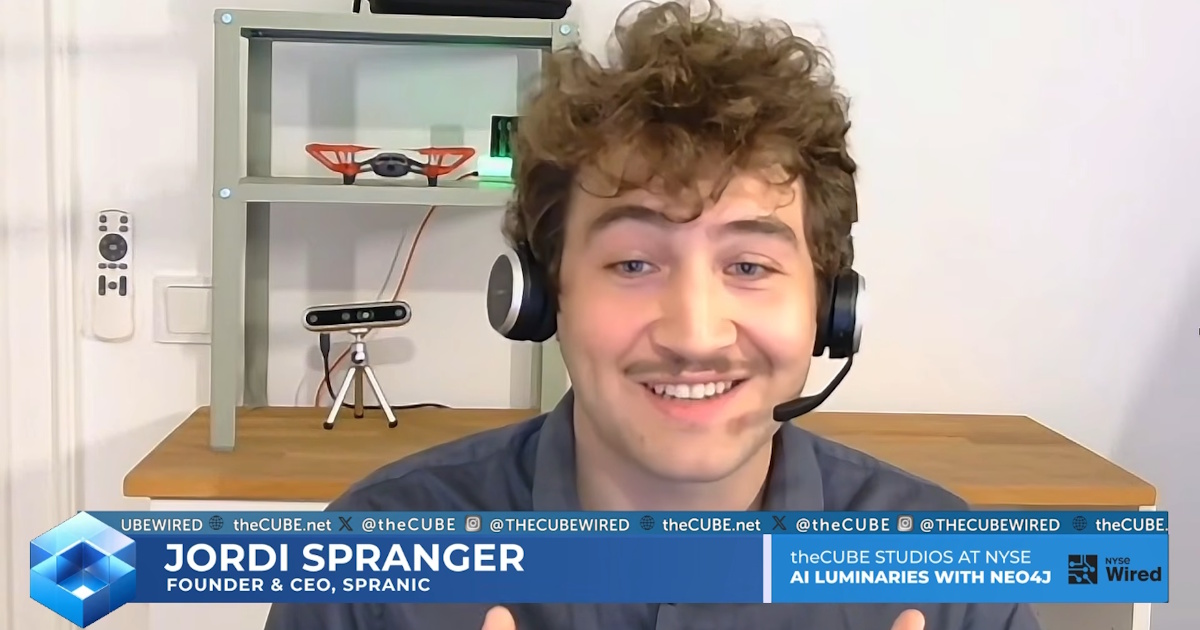
Munich-based startup Spranic is developing a spatial memory layer designed for physical AI applications. The technology aims to record physical environments and track changes within them, allowing robots to better adapt to their surroundings.
Founder and CEO Jordi Spranger stated that the system integrates spatial data with knowledge graphs. This approach is intended to help robots interpret environments across various tasks and move beyond static, pre-programmed instructions.
The company emphasizes the importance of data provenance, ensuring that robots can trace the origins of the information used to inform their actions. Knowledge graphs facilitate the connection of diverse data sources while maintaining auditability and safety.
Spranger noted that reusable spatial context can reduce the need for task-specific planning in robot deployments. The goal is to provide robots with a dynamic, high-fidelity mapping capability that enables them to replan and execute a wider range of human-like tasks.