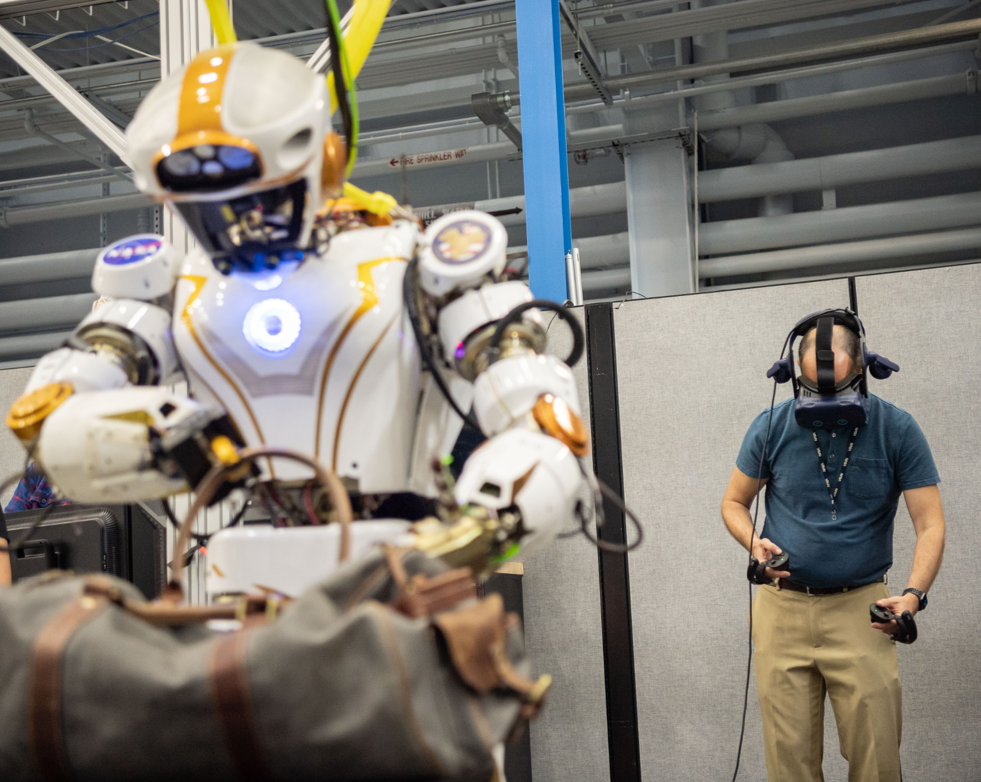
The Dexterous Robotics Team at NASA’s Johnson Space Center focuses on developing hardware and software for human-robot collaboration in space. The 16-member group operates within the Robotic System Technology Branch, specializing in systems capable of performing manual tasks in extreme environments.
The team builds on experience from previous projects, including the Robonaut 2, which spent seven years on the International Space Station, and the Valkyrie bipedal humanoid robot. Current efforts support various agency programs, including the development of a lunar base.
The team manages the Integrated Mobile Evaluation Testbed for Robotics Operations (iMETRO) facility. This center provides open-source software, simulations, habitat mockups, and testing areas for both NASA programs and private industry partners to adapt terrestrial robotics for space.
Recent collaborations include working with PickNik Inc. to test robotic arm software for hatch operations and cargo transfer. The team also supports interns in developing maintenance solutions for space station equipment, such as cold stowage freezers.
The team currently prioritizes technologies for sustained lunar presence, with future applications planned for Mars missions. They are also preparing a public challenge to solicit new technology solutions for Mars exploration.