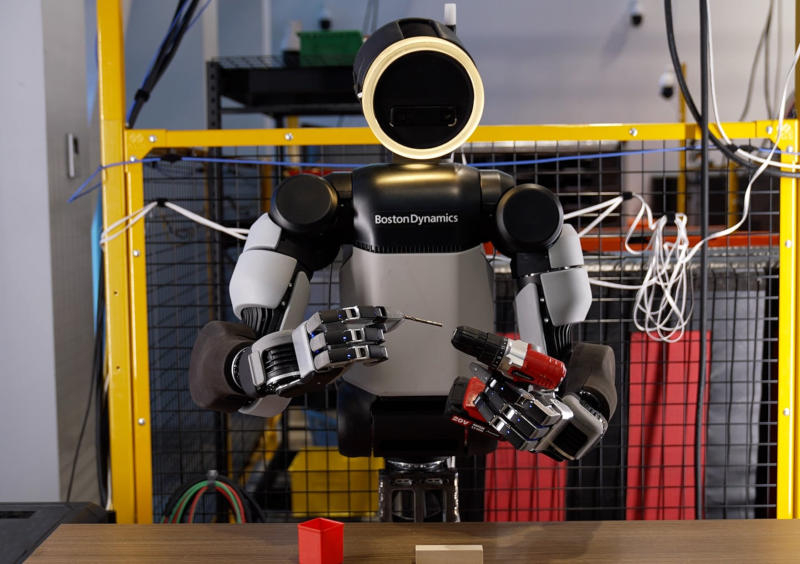
Boston Dynamics has introduced a new four-fingered hand design for its Atlas humanoid robot. The updated hands feature 13 degrees of freedom, a significant upgrade from the previous 7-degree-of-freedom model. The design includes a fully sealed actuator system to protect internal components.
The new hands are similar in size to human hands, allowing the robot to operate in human-centric environments. Despite their compact size, they can lift and carry objects weighing up to 45 kg. The hands are equipped with tactile pressure sensors and internal proprioception for real-time feedback.
The company opted for a four-finger configuration after determining that a fifth finger provided no functional advantage. The robot can perform precise grips, such as the pinch grip, and operate standard industrial tools like drills, screwdrivers, and grinders.
Training involves a combination of human demonstration and reinforcement learning in simulations. Engineers use human-worn gloves to record movements, which are then refined through simulation before being deployed to the physical robot to ensure effective manipulation in varied environments.