

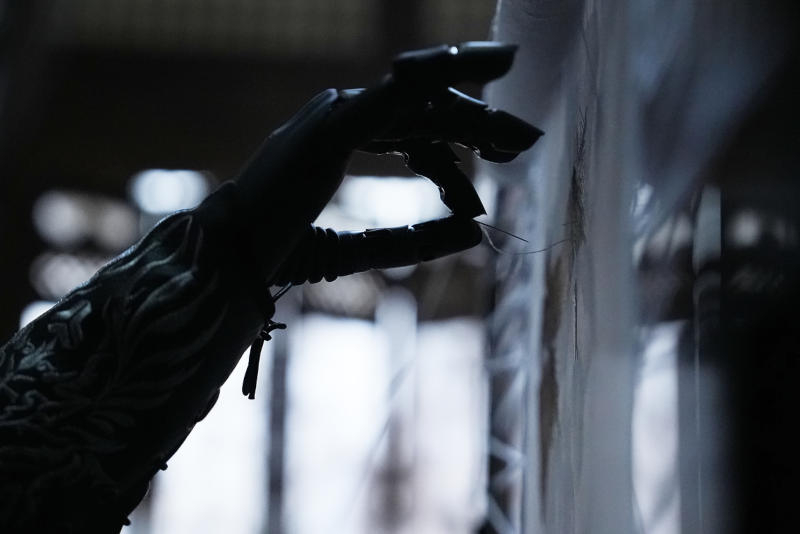
The Agilink company, a subsidiary of AgiBot, has trained the OmniHand 3 Ultra robotic arm to perform traditional Suzhou embroidery. The project involved collaboration with master embroiderer Fu Xianghong to teach the robot complex manual tasks, including threading needles, stretching fabric, and executing precise stitches.
A key technical challenge was mastering the separation of silk thread into 16 individual fibers. The robotic hand achieves this by using one finger for splitting while others maintain tension, mimicking the manual technique. The system relies on direct drive technology, eliminating tendons or intermediate transmission elements between the motor and joints.
The robotic arm weighs 630 grams and is designed to mimic human hand dimensions. It can hold objects weighing 3 kilograms and lift up to 8 kilograms. The device features a closing and opening cycle of approximately 0.3 seconds and maintains a movement repeatability accuracy of about 0.2 millimeters.
The robot utilizes optical sensors in its fingertips to detect surface changes and measure force across three axes, identifying deformations as small as 0.08 millimeters. Additionally, a 300-point contact sensor is integrated into the palm, allowing the system to distinguish between simple touch and object slippage.

